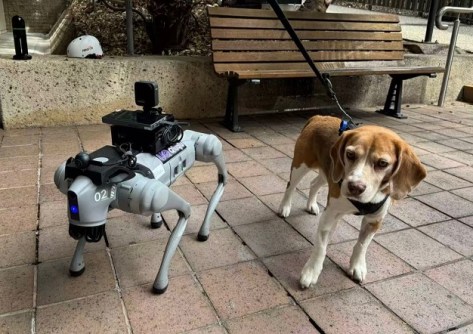
The University of Queensland VisLab is testing how robotic and spatial capture technologies could support research into accessibility across UQ’s St Lucia campus.
The research team brings together Dr Jurij Karlovsek, Assoc Prof Fred Fialho Teixeira, Dr Qianbin Xu, Dr Thien-Minh Nguyen and Dr Tyson Phillips, with Rui Zhang and Mohan Ren.
The initial trial examined an accessibility route between the VisLab and the UQ ferry terminal.
The research uses a Unitree Go2 quadruped robot, nicknamed QiuQiu, provided by Dr Nguyen, alongside complementary spatial capture technologies.
The team combined the robot’s internal motion data, its front facing camera and a 360-degree camera mounted on its back with handheld scanning, in which a researcher walked the same route carrying a handheld LiDAR scanner. This allowed researchers to compare robotic data collection with handheld scanning, and to investigate what additional spatial information each can capture.
Joining QiuQiu on the walk was Milo, a real dog, who left the measuring to the robot and carried out his own survey of the route.
A particular focus is the relationship between movement and accessibility. As QiuQiu walks, it records its pose, orientation and odometry, while its LiDAR scans the ground ahead and behind, revealing changes in slope and terrain along pedestrian routes.
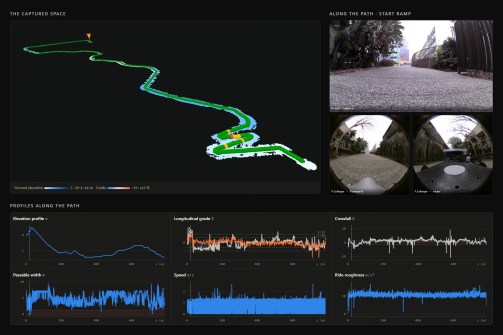
In the first full run, QiuQiu covered about 790 metres in roughly 13 minutes. Early analysis shows a route that is mostly gentle, with a net fall of about seven metres, a short ramp of around 1:9 near the start, and a long, gradual descent beyond it.
Repeated outward and return journeys can also provide comparable datasets for examining ramps, pathways and changing ground conditions through measurable spatial information.
The research may also inform future development of the Digital Twin of UQ St Lucia Campus, connecting accessibility information with broader spatial and infrastructure datasets.
Integrating route geometry, slope and mobility data within an interactive campus model could support universal access analysis and provide a stronger evidence base for future planning and decision making.